Predator Prey with Carrying Capacity
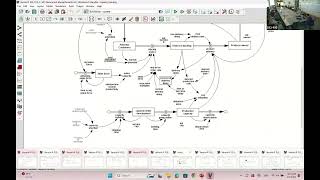
Hazhir Rahmandad continues MIT's course 15.879, Building Serious System Dynamics Models from Scratch, by extending the classic predator prey model to include carrying capacity limits on the prey population. He walks through constructing the causal loop diagram for the system, identifying which loops are reinforcing and which are balancing, and showing how a carrying capacity term changes the model's long run behavior compared to the unconstrained Lotka Volterra setup. The session is built around live model-building at the whiteboard and in simulation software, with Rahmandad narrating his modeling choices as he makes them rather than presenting a finished result. Running nearly two and a half hours, it is dense with worked detail on stock and flow structure and feedback loop identification, aimed at students who already have the basics of system dynamics and want to see a nontrivial model built from scratch.